Chu-Rong Chen

Robotics M.S. student at Georgia Tech. I build embedded control systems and robot software, from STM32 boards to learned policies.

NTUEE LightDanceOct 2023 – Mar 2024

Selected projects

Student Self-Landing VTVL Rocket

Avionics Team Lead, STAR
Nov 2023 – Oct 2025

Led early avionics architecture for a student VTVL rocket, coordinating with guidance, propulsion, and mechanical teams to define subsystem responsibilities and electrical interfaces.

Independently designed and laid out a multipurpose STM32 controller PCB with CAN, UART, I²C, and SPI interfaces for propulsion and thrust-vector-control applications; teammates later validated the prototype.
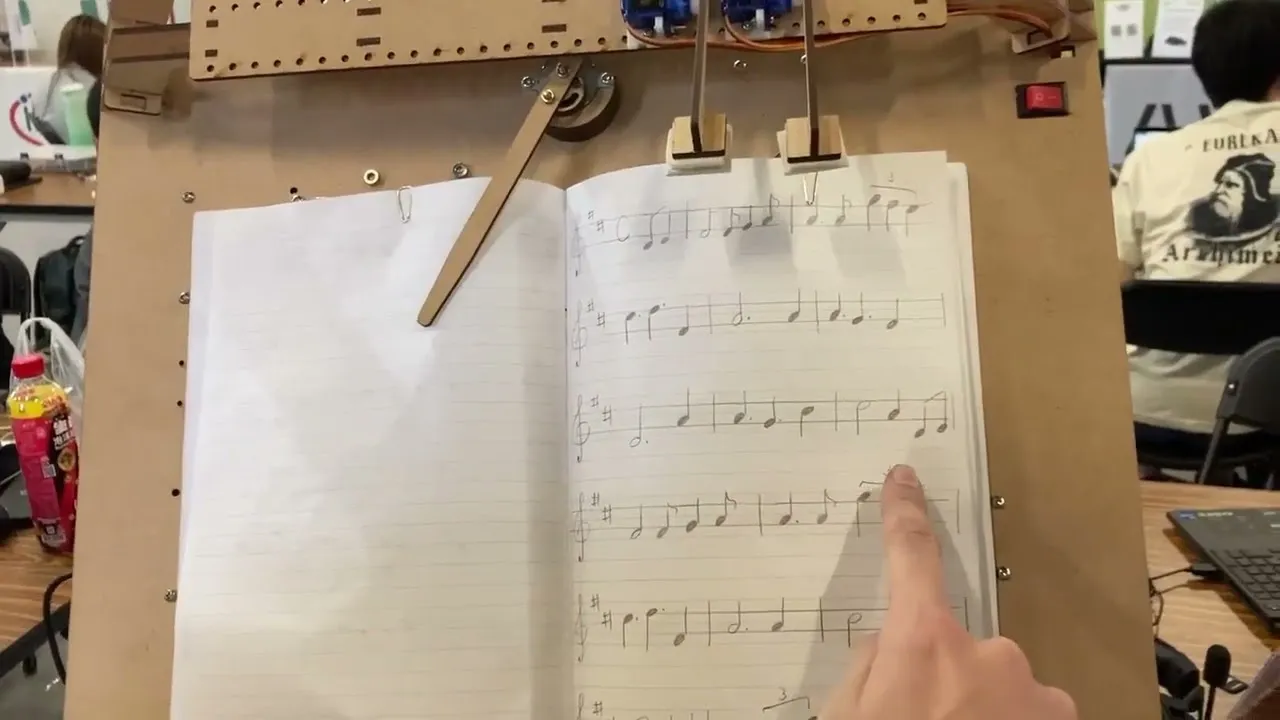
Learning Skill Abstraction from Action-Free Videos via Optical Flow

Undergraduate Researcher - Robot Learning, Robot Learning Lab, NTUEE
Aug 2022 – Aug 2025

Contributed to architecture design and core experiments for an imitation-learning model that uses optical flow as action primitives to learn from action-free demonstration videos; extended Meta-World and LIBERO for Sawyer and Panda arms and demonstrated cross-embodiment transfer.

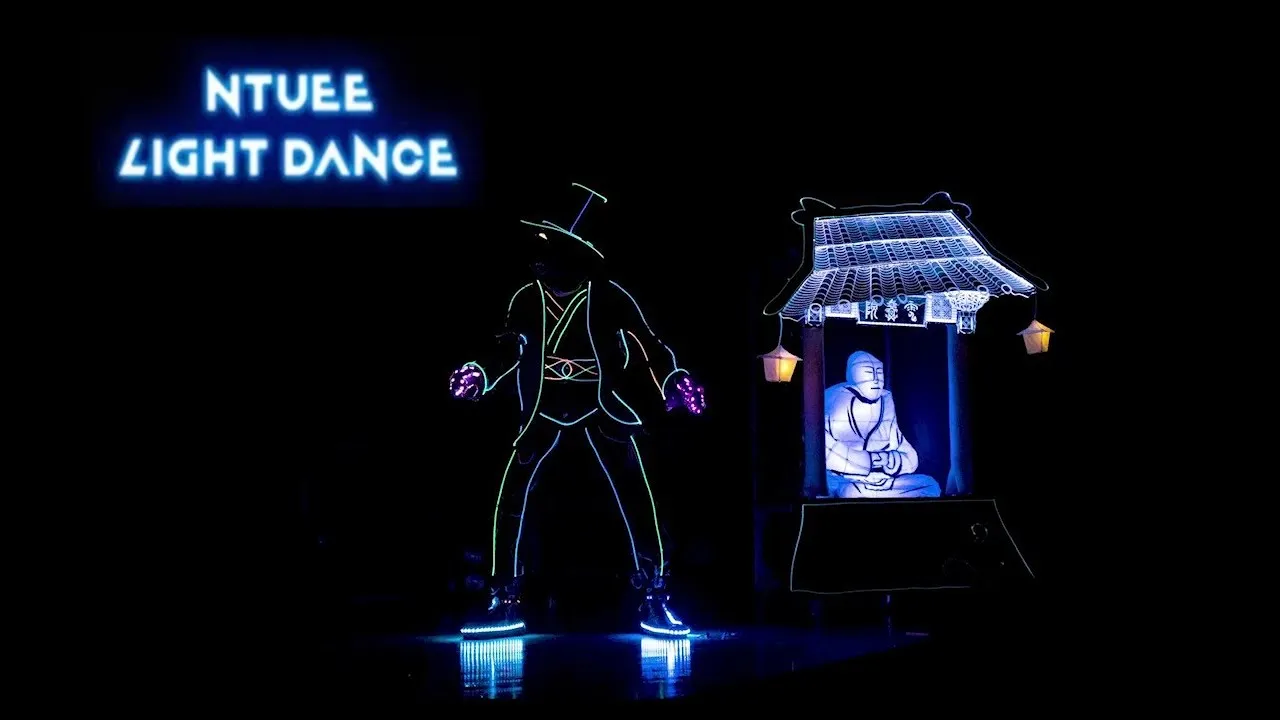
NTUEE LightDance

Software Team Lead, NTUEE LightDance
Oct 2023 – Mar 2024

Co-led a 10-member software team, owning the light-show editor and backend and coordinating their interfaces with the Raspberry Pi control team.

Rewrote the TypeScript backend in Rust using SQLx and GraphQL for typed and efficient processing of deeply nested lighting data. The new backend supported multi-user editing of scenes with 5,000+ LEDs and 1,000+ keyframes and cut per-frame saves from 2–3 seconds to a few hundred milliseconds.

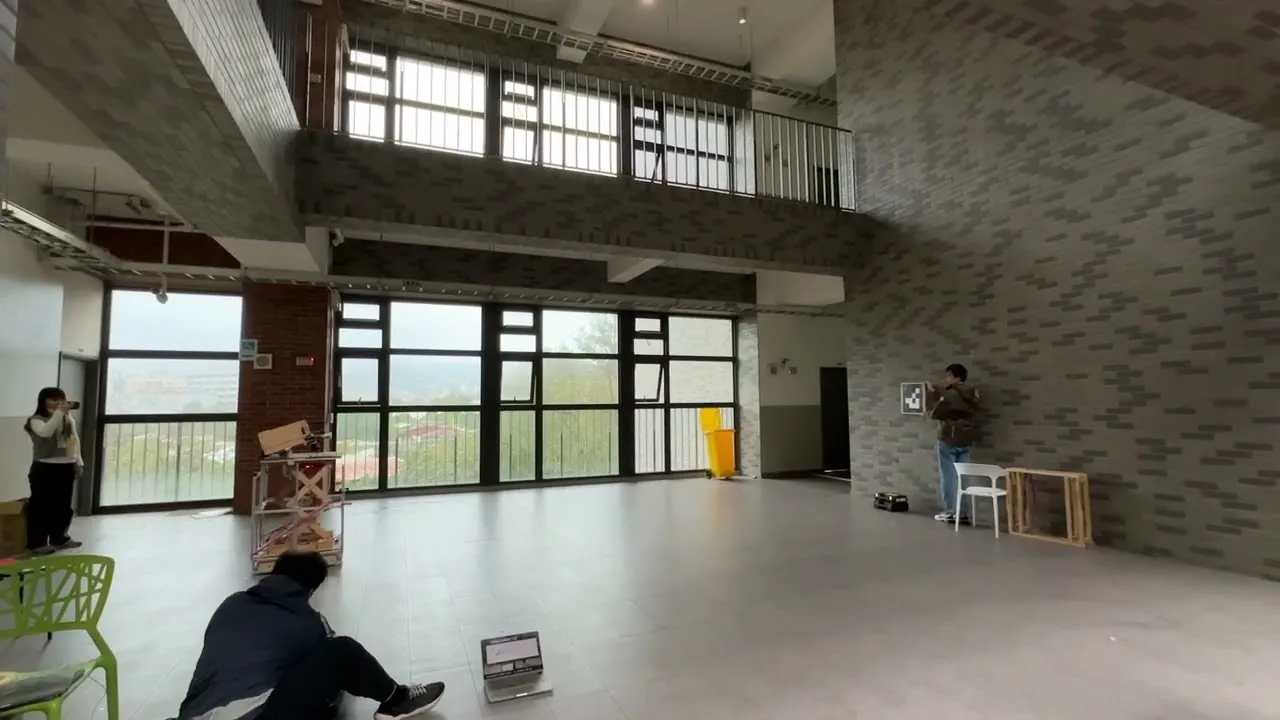
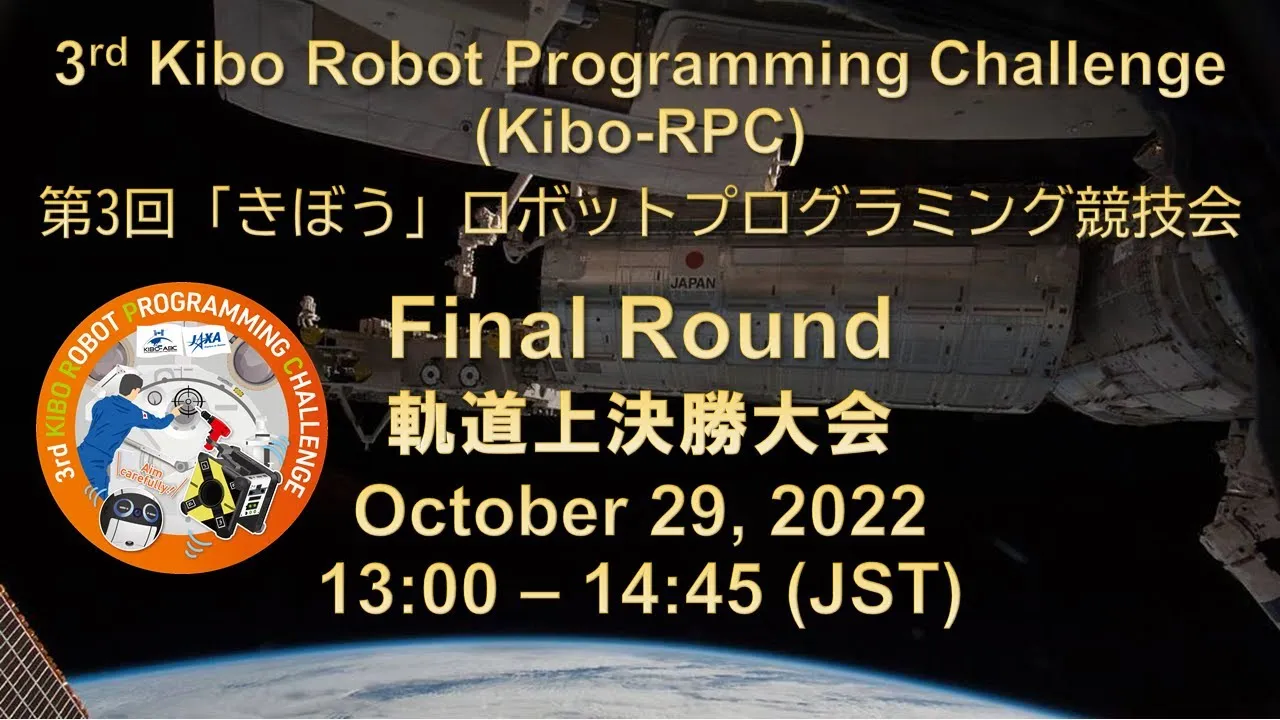
Kibo RPC

World Champion, Navigation Team Lead
Jun 2022 – Oct 2022

Led navigation development for an autonomous robot aboard the ISS, combining circle-based target detection and ArUco pose estimates with a Dijkstra planner that routed around polygonal keepout zones.

Chose repeated pose correction and conservative motion for final target engagement; the team earned full shooting points in its final competition run and the highest overall score worldwide.

More projects

No photo yet

3D scene reconstruction (NeRF / 3D Gaussian Splatting / sparse voxel octrees)

Undergraduate Researcher - 3D Scene Reconstruction, Vision & Learning Lab, NTUEE, Jul 2024 – Nov 2025

Investigated Neural Radiance Fields (NeRF) and 3D Gaussian Splatting for static and dynamic scene reconstruction, with a focus on dynamic scenes.

Differentiable sim-to-real RL (JAX + NVIDIA Warp)

Undergraduate Researcher - Robot Learning, Robot Learning Lab, NTUEE, Aug 2022 – Aug 2025

Independently initiated a differentiable sim-to-real RL project using JAX and NVIDIA Warp to correct simulator dynamics from target trajectories; evaluated locomotion policies under simulated dynamics shifts.

No photo yet

Mobile ALOHA pipeline

Undergraduate Researcher - Robot Learning, Robot Learning Lab, NTUEE, Aug 2022 – Aug 2025

Co-built a Mobile ALOHA pipeline spanning ROS 2 data collection, camera calibration, optical-flow estimation, model training, and on-robot inference.

Automatic Frisbee Shooter

Sep 2023 – Dec 2023

Designed and built the four-wheel robot's mechanical structure, power system, and automated frisbee loading and lifting mechanisms.

MusicTracker

May 2023

Built an STM32 audio pipeline using I2S, DMA, and CMSIS-DSP to compute Mel spectrograms from live performance.

No photo yet

Furuta Pendulum

Dec 2022

Linearized a provided Furuta pendulum model, designed and tuned an LQR controller in MATLAB/Simulink, and tested upright stabilization and disturbance recovery on course hardware.

No photo yet

Intelligent Shopping Cart

Patent, Full-System Developer, Jan 2020 – Apr 2020

Built a BLE-based shopping-cart prototype for indoor product navigation and checkout; the integrated design received a Taiwan utility model patent.

Experience

  1. Dec 2025 – Jul 2026

    Tensor Tech CO., LTD.

    Embedded Engineering Intern

    • Developed a self-describing telemetry framework for 5-kHz embedded control firmware, using statically registered metadata, preallocated buffers, and fixed-offset binary writes to minimize runtime overhead; built host-side decoding tools adopted for control experiments and agentic workflows.
    • Independently designed and built a rotor-balancing prototype, integrating mechanical structures, multi-axis force sensing, fiber-optic phase triggering, and signal processing to estimate unbalance and recommend corrections; calibrated using known trial masses.
    • Designed and validated a projector-based solar simulator using optical simulation and pixel-level intensity compensation, achieving 2.4° beam divergence (target: <3°) and <3% illumination variation across a 5×5 cm² area.
    • Extended the measurement platform for micro-vibration characterization of gyros, automating stepped-speed sweeps and six-axis force/torque spectral analysis with waterfall visualization on an air-bearing-isolated test setup.
  2. Jul 2024 – Nov 2025

    Vision & Learning Lab, NTUEE

    Undergraduate Researcher - 3D Scene Reconstruction

    • 3D scene reconstruction (NeRF / 3D Gaussian Splatting / sparse voxel octrees)
  3. Jun 2025 – Aug 2025

    Ambarella Inc.

    Software Engineering Intern - Embedded AI, Algorithm, Tools

    • Evaluated ParamISP and implemented ISO-conditioned low-rank adapters in a motion-detection CNN; introduced shared pretraining and range-specific fine-tuning, reducing total training time by about 80% versus training the previous models separately while improving test loss.
    • Refactored the legacy training pipeline with PyTorch Lightning, moving scattered parameters into configuration files, standardizing dataset processing, and adding Weights & Biases tracking to make experiments easier to configure and compare.
  4. Aug 2022 – Aug 2025

    Robot Learning Lab, NTUEE

    Undergraduate Researcher - Robot Learning

  5. 2023 – 2025

    National Taiwan University, Department of Electrical Engineering

    Teaching Assistant

    • Mentored first-year students in systems-engineering projects integrating Arduino hardware and Python software for autonomous mechatronic systems.
    • Led tutorials and provided technical support on signal-processing fundamentals, Fourier analysis, and linear systems.
  6. Jul 2023 – Aug 2023

    Institute of Information Science, Academia Sinica

    Algorithm Summer Intern

    • Accelerated a post-quantum cryptographic signature scheme using AVX2 SIMD instructions, achieving a 5× speedup over the baseline implementation.
    • Maintained constant-time execution to mitigate timing side-channel attacks while achieving a 5× speedup over the baseline implementation.

About

I studied electrical engineering at National Taiwan University, where I did robot-learning and 3D-reconstruction research and led student teams on a space-robotics challenge, a self-landing rocket and a light-dance show. I have interned at Tensor Tech, Ambarella and Academia Sinica.

Education

  • M.S. in Robotics, Georgia Institute of Technology
    Aug 2026 – Dec 2027
  • B.S. in Engineering – Electrical Engineering, National Taiwan University
    Sep 2021 – Jan 2026

Publication

Learning Skill Abstraction from Action-Free Videos via Optical Flow — ICML 2025 Workshop
Hung-Chieh Fang*, Kuo-Han Hung*, Chu-Rong Chen, Po-Jung Chou, Chun-Kai Yang, Po-Chen Ko, et al.

Skills

Languages
Mandarin (Native), English (Fluent, TOEFL 115)
Programming
C/C++, Python, Rust, CUDA, TypeScript, JavaScript
ML / Robotics
PyTorch, TensorFlow, JAX, OpenCV, ROS 2, MuJoCo, DeepSpeed, PyTorch Lightning
Platform / Tools
STM32, Raspberry Pi, Git, Docker, MATLAB/Simulink, Fusion 360, AutoCAD, KiCad